collaborators
for the projects and papers

555 your office number
123 your address street
Your City, State 12345
layout: portfolio title: Hanli Zhang permalink: / description: Robotics researcher building learning-enabled systems for autonomy, perception, planning, and human-robot interaction. —
ROBOTICS · AI/ML · AUTONOMOUS SYSTEMS
Building intelligent systems
from models to motion.
I’m 张涵俐 Hanli Zhang, a robotics researcher at EPFL LASA under the supervision of Prof. Aude Billard, based in Lausanne, Switzerland.
My work connects learning, planning, perception, and control—then tests the result on real robotic systems.

SELECTED WORK
Evidence, not just keywords.
Projects spanning aerial robotics, embedded perception, robot learning, and visual SLAM—with demos, code, papers, and reports where available.
Drag-Aware Quadrotor Planning & Sim-to-Real Validation
Learned a tracking-cost model from 200,000 simulated trajectories and integrated it into trajectory optimization with an SE(3) controller, then validated the planner on Crazyflie hardware.
F1TENTH Depth-Based Navigation
Built a monocular-depth perception and navigation stack combining MiDaS, rangefinder calibration, and depth-guided Follow-the-Gap control. Optimized inference with ONNX/TensorRT for edge deployment.
Gaussian Splatting SLAM with Loop Closure
Extended MonoGS with loop closure, Gaussian-aware covisibility, pose-graph optimization, global bundle adjustment, and CUDA rasterizer visibility metrics.
Task Planning & Evaluation for Robot Manipulation
Supervised and evaluated a planner using structured action primitives, feedback loops, recovery logic, and retune-vs-replan decisions.
EXPERIENCE
Research depth. Field-tested engineering.
Experience across human-robot interaction, mobile robots, aerial systems, state estimation, and deployment debugging.
Robotics Researcher
Researching coordination-aware modeling for multi-limb human-robot interaction, combining stable dynamical-system motion primitives with cross-limb coupling.
Robotic Engineer Intern
Built a VINS-Fusion visual-inertial state-estimation pipeline with panoramic camera and IMU data, reducing outdoor tracking error by 15%.
Algorithm Engineer
Improved AGV localization to ±5 mm pose accuracy, reduced pose-loss events by 30%, refactored 12 ROS/C++ modules, and resolved 30+ field issues.
TOOLKIT
Built for the full robotics stack.
Robotics
ROS1/2, SLAM, localization, mapping, state estimation, sensor fusion
Planning & control
Optimal control, motion planning, trajectory optimization, dynamical systems
AI & perception
PyTorch, JAX, TensorFlow, OpenCV, LLM planning and evaluation
Deployment
C/C++, Python, ONNX, TensorRT, NVIDIA Jetson, Linux, Docker, Git
INDEPENDENT PROJECT
Beyond robotics.
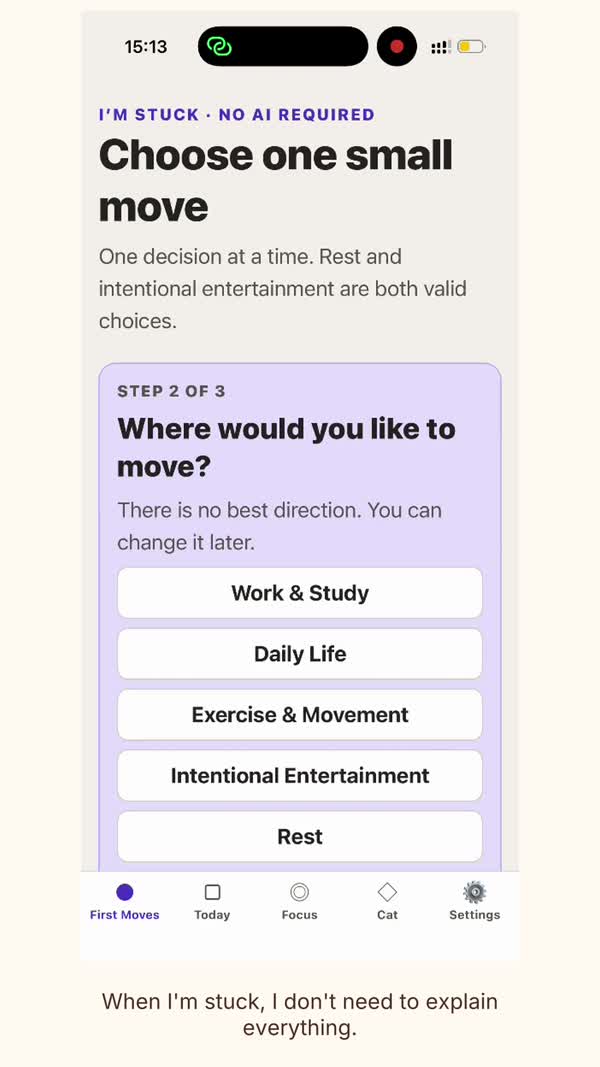
Personal project · iOS + Web · In development
First Move
A cross-platform app that helps people turn a stuck moment into one small, time-boxed action. I built the app flows, persistent focus sessions, and web/mobile account sync.
ROBOTICS RÉSUMÉ
Robotics experience, one focused page.
The project, paper, code, and report links inside the PDF are clickable.
555 your office number
123 your address street
Your City, State 12345
layout: portfolio title: Hanli Zhang permalink: / description: Robotics researcher building learning-enabled systems for autonomy, perception, planning, and human-robot interaction. —
ROBOTICS · AI/ML · AUTONOMOUS SYSTEMS
Building intelligent systems
from models to motion.
I’m 张涵俐 Hanli Zhang, a robotics researcher at EPFL LASA under the supervision of Prof. Aude Billard, based in Lausanne, Switzerland.
My work connects learning, planning, perception, and control—then tests the result on real robotic systems.
SELECTED WORK
Evidence, not just keywords.
Projects spanning aerial robotics, embedded perception, robot learning, and visual SLAM—with demos, code, papers, and reports where available.
Drag-Aware Quadrotor Planning & Sim-to-Real Validation
Learned a tracking-cost model from 200,000 simulated trajectories and integrated it into trajectory optimization with an SE(3) controller, then validated the planner on Crazyflie hardware.
F1TENTH Depth-Based Navigation
Built a monocular-depth perception and navigation stack combining MiDaS, rangefinder calibration, and depth-guided Follow-the-Gap control. Optimized inference with ONNX/TensorRT for edge deployment.
Gaussian Splatting SLAM with Loop Closure
Extended MonoGS with loop closure, Gaussian-aware covisibility, pose-graph optimization, global bundle adjustment, and CUDA rasterizer visibility metrics.
Task Planning & Evaluation for Robot Manipulation
Supervised and evaluated a planner using structured action primitives, feedback loops, recovery logic, and retune-vs-replan decisions.
EXPERIENCE
Research depth. Field-tested engineering.
Experience across human-robot interaction, mobile robots, aerial systems, state estimation, and deployment debugging.
Robotics Researcher
Researching coordination-aware modeling for multi-limb human-robot interaction, combining stable dynamical-system motion primitives with cross-limb coupling.
Robotic Engineer Intern
Built a VINS-Fusion visual-inertial state-estimation pipeline with panoramic camera and IMU data, reducing outdoor tracking error by 15%.
Algorithm Engineer
Improved AGV localization to ±5 mm pose accuracy, reduced pose-loss events by 30%, refactored 12 ROS/C++ modules, and resolved 30+ field issues.
TOOLKIT
Built for the full robotics stack.
Robotics
ROS1/2, SLAM, localization, mapping, state estimation, sensor fusion
Planning & control
Optimal control, motion planning, trajectory optimization, dynamical systems
AI & perception
PyTorch, JAX, TensorFlow, OpenCV, LLM planning and evaluation
Deployment
C/C++, Python, ONNX, TensorRT, NVIDIA Jetson, Linux, Docker, Git
INDEPENDENT PROJECT
Beyond robotics.
Personal project · iOS + Web · In development
First Move
A cross-platform app that helps people turn a stuck moment into one small, time-boxed action. I built the app flows, persistent focus sessions, and web/mobile account sync.
ROBOTICS RÉSUMÉ
Robotics experience, one focused page.
The project, paper, code, and report links inside the PDF are clickable.